---
title: RoboBrain-LoRA-Affordance
canonical_url: "https://www.modelscope.cn/models/BAAI/RoboBrain-LoRA-Affordance"
md_url: "https://www.modelscope.cn/models/BAAI/RoboBrain-LoRA-Affordance.md"
repository: BAAI/RoboBrain-LoRA-Affordance
last_updated: 2025-04-04
license: apache-2.0
parameters: 173.0M
tensor_type:
- F16
library_name:
- safetensors
- pytorch
frameworks:
- pytorch
language:
- en
downloads: 586
stars: 0
---
# RoboBrain-LoRA-Affordance
> RoboBrain-LoRA-Affordance - BAAI 在 ModelScope 开源的模型。[CVPR 25] RoboBrain: A Unified Brain Model for Robotic Manipulation from Abstract to Concrete.
BAAI/RoboBrain-LoRA-Affordance 是 ModelScope 魔搭社区上的 173.0M 参数机器学习模型,采用 apache-2.0 许可。
- **Repository**: BAAI/RoboBrain-LoRA-Affordance
- **License**: apache-2.0
- **Parameters**: 173.0M
- **Downloads**: 586
- **Stars**: 0
- **Last updated**: 2025-04-04
Source: https://www.modelscope.cn/models/BAAI/RoboBrain-LoRA-Affordance
---
# [CVPR 25] RoboBrain: A Unified Brain Model for Robotic Manipulation from Abstract to Concrete.
## 🤗 Models
- **[`Base Planning Model`](https://huggingface.co/BAAI/RoboBrain/)**: The model was trained on general datasets in Stages 1–2 and on the Robotic Planning dataset in Stage 3, which is designed for Planning prediction.
- **[`A-LoRA for Affordance`](https://huggingface.co/BAAI/RoboBrain-LoRA-Affordance/)**: Based on the Base Planning Model, Stage 4 involves LoRA-based training with our Affordance dataset to predict affordance.
- **[`T-LoRA for Trajectory`](https://huggingface.co/BAAI/RoboBrain/)**: Based on the Base Planning Model, Stage 4 involves LoRA-based training with our Trajectory dataset to predict trajectory.
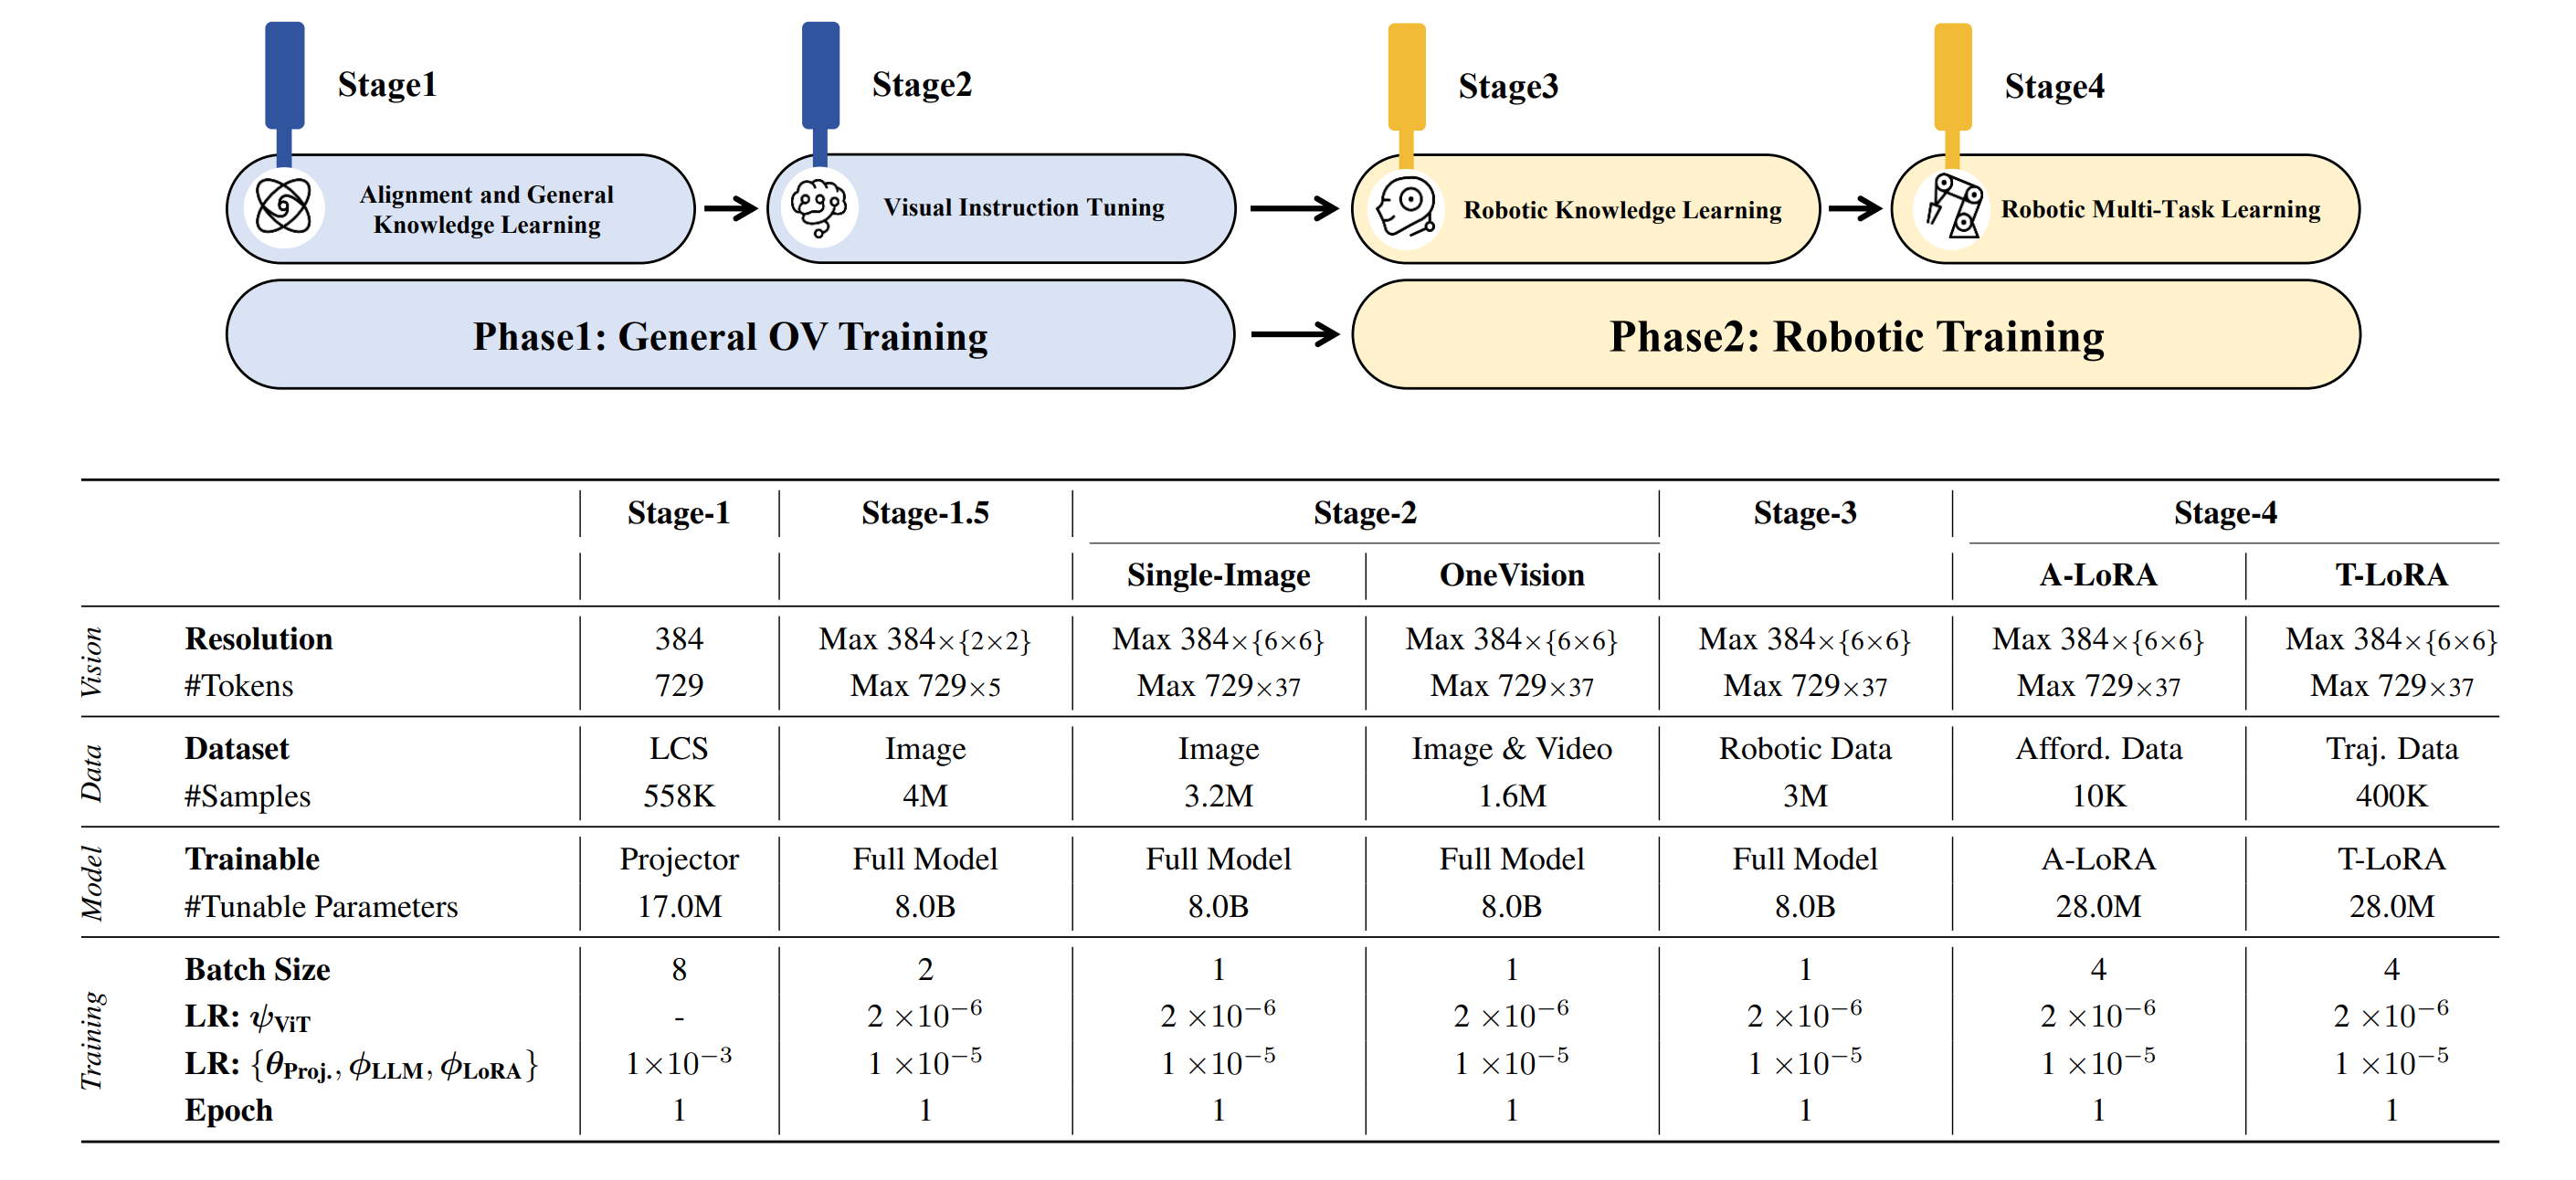
| Models | Checkpoint | Description |
|----------------------|----------------------------------------------------------------|------------------------------------------------------------|
| Planning Model | [🤗 Planning CKPTs](https://huggingface.co/BAAI/RoboBrain/) | Used for Planning prediction in our paper |
| Affordance (A-LoRA) | [🤗 Affordance CKPTs](https://huggingface.co/BAAI/RoboBrain-LoRA-Affordance/) | Used for Affordance prediction in our paper |
| Trajectory (T-LoRA) | [🤗 Trajectory CKPTs](https://huggingface.co/BAAI/RoboBrain-LoRA-Trajectory/) | Used for Trajectory prediction in our paper |
## 🛠️ Setup
```bash
# clone repo.
git clone https://github.com/FlagOpen/RoboBrain.git
cd RoboBrain
# build conda env.
conda create -n robobrain python=3.10
conda activate robobrain
pip install -r requirements.txt
```
## 🤖 Training
### 1. Data Preparation
```bash
# Modify datasets for Stage 4_aff, please refer to:
- yaml_path: scripts/train/yaml/stage_4_affordance.yaml
```
**Note:** During training, we applied normalization to the bounding boxes, representing them with the coordinates of the top-left and bottom-right corners, and retaining three decimal places for each.
The sample format in each json file should be like:
```json
{
"id": xxxx,
"image": "testsetv3/Unseen/egocentric/ride/bicycle/bicycle_001662.jpg",
"conversations": [
{
"value": "\nYou are a robot using the joint control. The task is \"ride the bicycle\". Please predict a possible affordance area of the end effector?",
"from": "human"
},
{
"from": "gpt",
"value": "[0.561, 0.171, 0.645, 0.279]"
}
]
},
```
### 2. Training
```bash
# Training on Stage 4_aff:
bash scripts/train/stage_4_0_resume_finetune_lora_a.sh
```
**Note:** Please change the environment variables (e.g. *DATA_PATH*, *IMAGE_FOLDER*, *PREV_STAGE_CHECKPOINT*) in the script to your own.
### 3. Convert original weights to HF weights
```bash
# Planning Model
python model/llava_utils/convert_robobrain_to_hf.py --model_dir /path/to/original/checkpoint/ --dump_path /path/to/output/
# A-LoRA & T-RoRA
python model/llava_utils/convert_lora_weights_to_hf.py --model_dir /path/to/original/checkpoint/ --dump_path /path/to/output/
```
## ⭐️ Inference
### Usage for Affordance Prediction
```python
# please refer to https://github.com/FlagOpen/RoboBrain
from inference import SimpleInference
model_id = "BAAI/RoboBrain"
lora_id = "BAAI/RoboBrain-LoRA-Affordance"
model = SimpleInference(model_id, lora_id)
# Example 1:
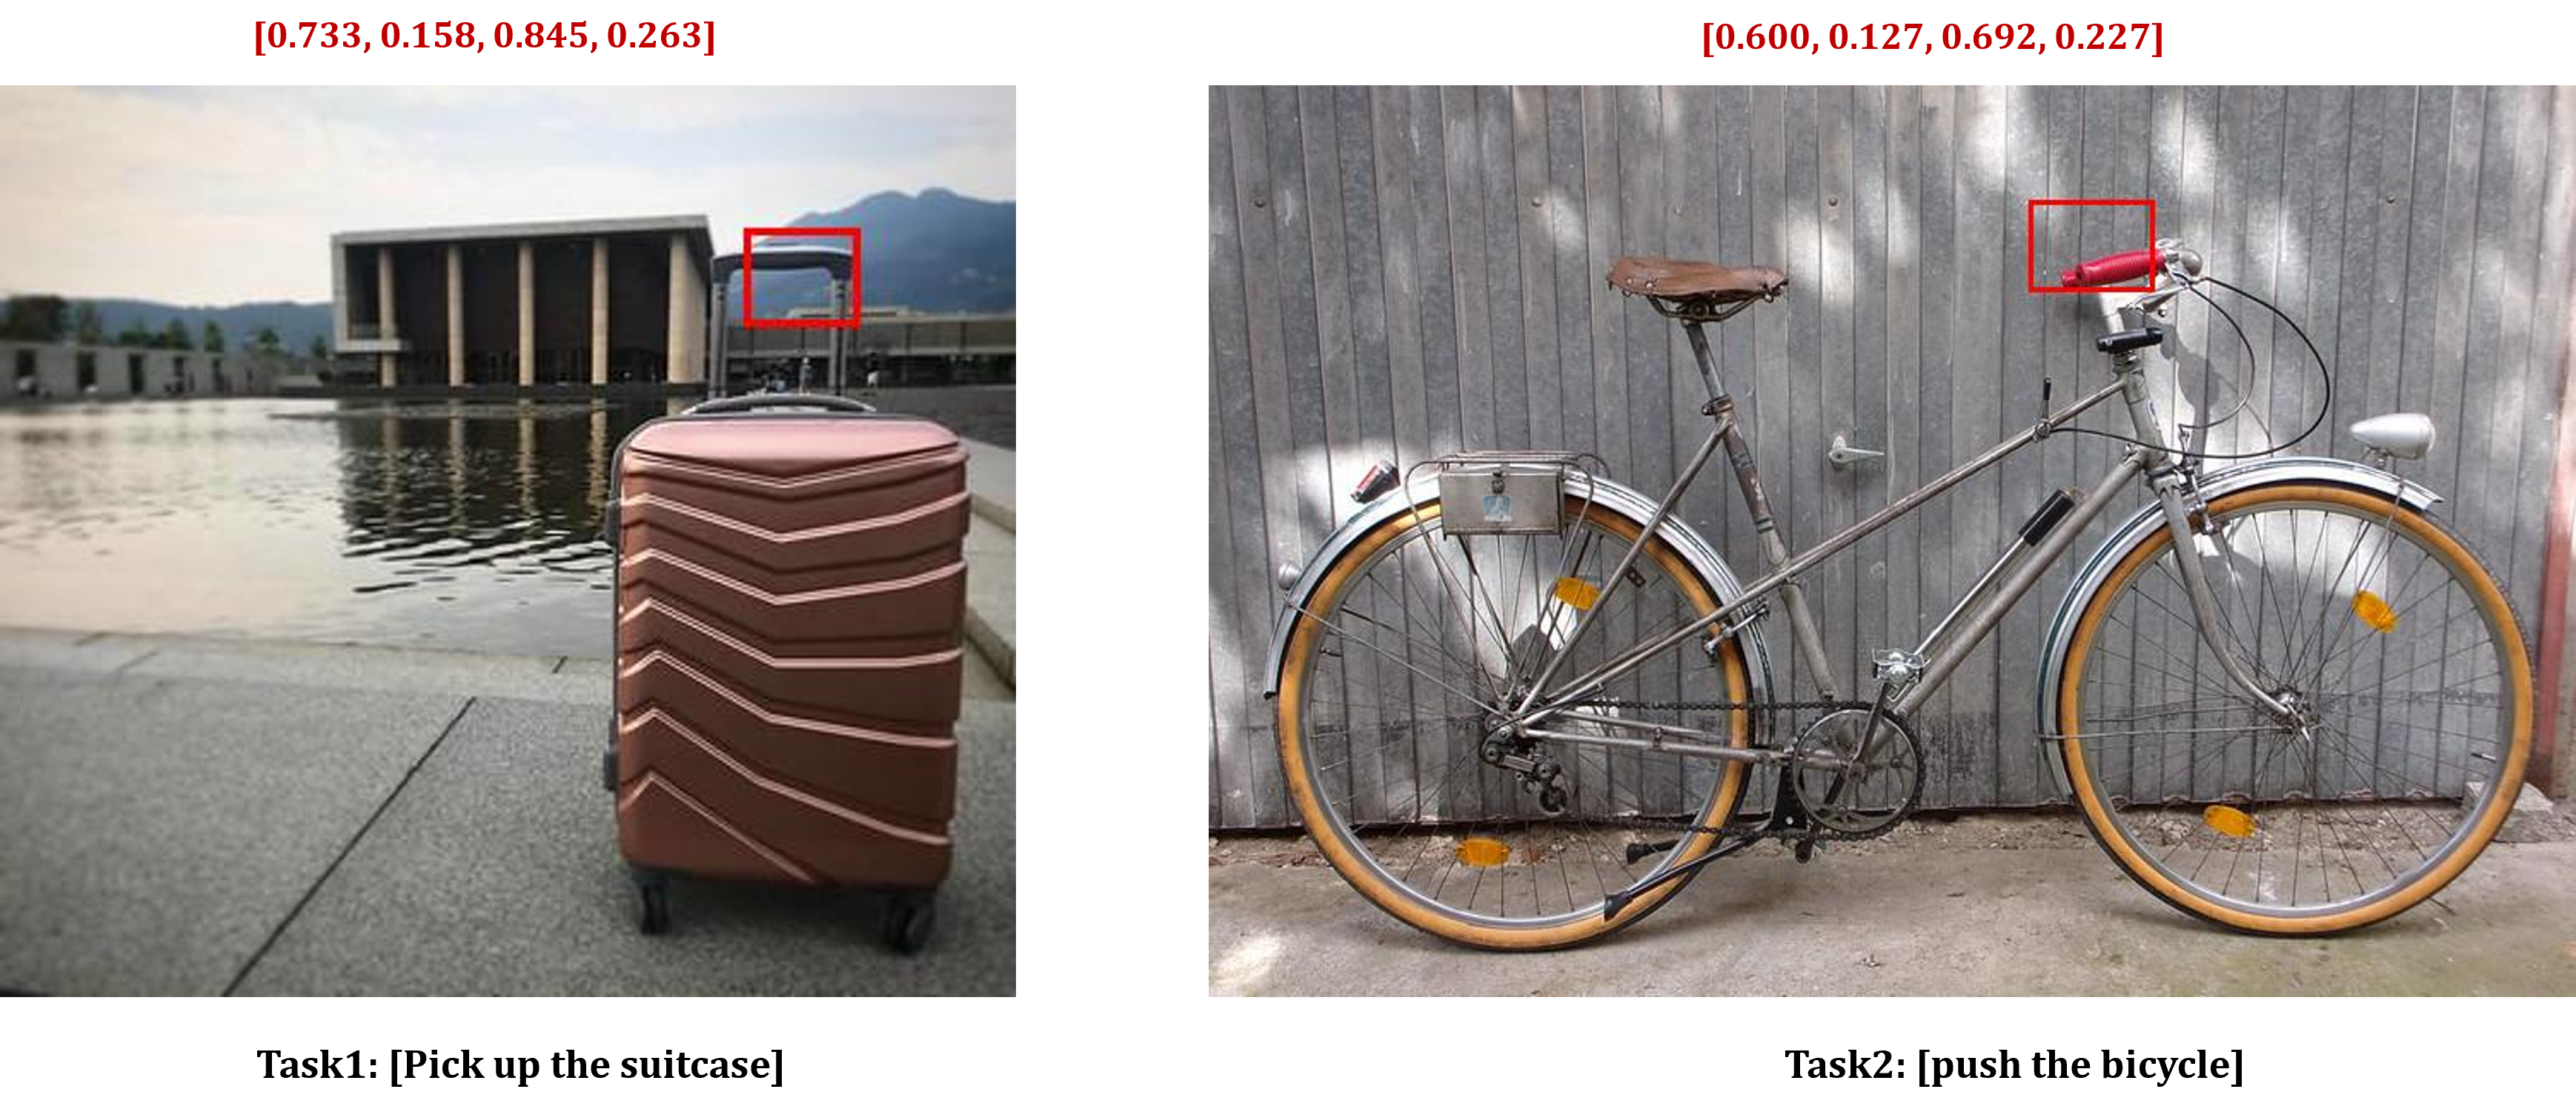
prompt = "You are a robot using the joint control. The task is \"pick_up the suitcase\". Please predict a possible affordance area of the end effector?"
image = "./assets/demo/affordance_1.jpg"
pred = model.inference(prompt, image, do_sample=False)
print(f"Prediction: {pred}")
'''
Prediction: [0.733, 0.158, 0.845, 0.263]
'''
# Example 2:
prompt = "You are a robot using the joint control. The task is \"push the bicycle\". Please predict a possible affordance area of the end effector?"
image = "./assets/demo/affordance_2.jpg"
pred = model.inference(prompt, image, do_sample=False)
print(f"Prediction: {pred}")
'''
Prediction: [0.600, 0.127, 0.692, 0.227]
'''
```
## 🤖 Evaluation
*Coming Soon ...*
## 😊 Acknowledgement
We would like to express our sincere gratitude to the developers and contributors of the following projects:
1. [LLaVA-NeXT](https://github.com/LLaVA-VL/LLaVA-NeXT): The comprehensive codebase for training Vision-Language Models (VLMs).
2. [Open-X-Emboddied](https://github.com/EvolvingLMMs-Lab/lmms-eval): A powerful evaluation tool for Vision-Language Models (VLMs).
3. [AGD20k](https://github.com/lhc1224/Cross-View-AG): An affordance dataset that provides instructions and corresponding affordance regions.
Their outstanding contributions have played a pivotal role in advancing our research and development initiatives.
## 📑 Citation
If you find this project useful, welcome to cite us.
```bib
@article{ji2025robobrain,
title={RoboBrain: A Unified Brain Model for Robotic Manipulation from Abstract to Concrete},
author={Ji, Yuheng and Tan, Huajie and Shi, Jiayu and Hao, Xiaoshuai and Zhang, Yuan and Zhang, Hengyuan and Wang, Pengwei and Zhao, Mengdi and Mu, Yao and An, Pengju and others},
journal={arXiv preprint arXiv:2502.21257},
year={2025}
}
```
