---
title: ActiveScale
canonical_url: "https://www.modelscope.cn/datasets/shuai302/ActiveScale"
md_url: "https://www.modelscope.cn/datasets/shuai302/ActiveScale.md"
repository: shuai302/ActiveScale
last_updated: 2026-09-19
license: "Apache License 2.0"
downloads: 3809
stars: 1
---

# ActiveScale

> ActiveScale - shuai302 在 ModelScope 开源的数据集。ActiveScale Active Perception Dataset
shuai302/ActiveScale 是 ModelScope 魔搭社区上的数据集，采用 Apache License 2.0 许可。

- **Repository**: shuai302/ActiveScale
- **License**: Apache License 2.0
- **Downloads**: 3809
- **Stars**: 1
- **Last updated**: 2026-09-19

Source: https://www.modelscope.cn/datasets/shuai302/ActiveScale

---

<h1 align="center">ActiveScale Active Perception Dataset</h1>

<p align="center">
  <a href="https://arxiv.org/abs/2609.18514"><img src="https://img.shields.io/badge/arXiv-B31B1B?style=for-the-badge&logo=arxiv&logoColor=white" alt="arXiv"></a>
  <a href="https://active-scale.github.io/"><img src="https://img.shields.io/badge/Project_Page-4285F4?style=for-the-badge&logo=googlechrome&logoColor=white" alt="Project page"></a>
  <a href="https://youtu.be/Iya0bSZ8Dko"><img src="https://img.shields.io/badge/YouTube-FF0000?style=for-the-badge&logo=youtube&logoColor=white" alt="YouTube"></a>
  <a href="https://github.com/ShuaiZhou302/ActiveScale"><img src="https://img.shields.io/badge/GitHub-181717?style=for-the-badge&logo=github&logoColor=white" alt="GitHub"></a>
  <a href="https://huggingface.co/davidzhou302/ActiveScale"><img src="https://img.shields.io/badge/Model_Checkpoints-FFD21E?style=for-the-badge&logo=huggingface&logoColor=black" alt="Model checkpoints"></a>
</p>

<p align="center">
  <a href="https://active-scale.github.io/">
    <img src="https://raw.githubusercontent.com/active-scale/active-scale.github.io/main/assets/teaser_1.webp" alt="ActiveScale overview" width="100%">
  </a>
</p>

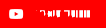
<p align="center">
  This release contains teleoperated demonstrations collected with the<br>
  Active-perception Mobile-manipulation Platform (AMP). Each HDF5 file stores<br>
  one synchronized robot episode with observations and actions.
</p>

<table align="center">
  <thead>
    <tr><th>Directory</th><th>Task</th><th>Episodes</th></tr>
  </thead>
  <tbody>
    <tr><td><code>backpack</code></td><td>Pick objects from a backpack</td><td align="right">151</td></tr>
    <tr><td><code>drawer</code></td><td>Pick objects from a drawer</td><td align="right">150</td></tr>
    <tr><td><code>pot</code></td><td>Pick objects from a shelf and place them in a pot</td><td align="right">151</td></tr>
    <tr><td><code>box</code></td><td>Pick objects from a shelf and place them in a box</td><td align="right">150</td></tr>
    <tr><td><code>under_table</code></td><td>Sort objects under a table</td><td align="right">151</td></tr>
  </tbody>
</table>

<p align="center">
  Training code and data-format documentation are available in the
  <a href="https://github.com/ShuaiZhou302/ActiveScale">ActiveScale repository</a>.
</p>