---
title: BiDex-100
canonical_url: "https://www.modelscope.cn/datasets/Robbyant-Research/BiDex-100"
md_url: "https://www.modelscope.cn/datasets/Robbyant-Research/BiDex-100.md"
repository: Robbyant-Research/BiDex-100
last_updated: 2026-10-28
license: other
storage_size: "195 GB"
downloads: 30069
stars: 0
---
# BiDex-100
> BiDex-100 - Robbyant-Research 在 ModelScope 开源的数据集。A comprehensive benchmark for bimanual dexterous manipulation across 100+ simulation tasks
Robbyant-Research/BiDex-100 是 ModelScope 魔搭社区上的数据集,存储大小 195 GB,采用 other 许可。
- **Repository**: Robbyant-Research/BiDex-100
- **License**: other
- **Storage size**: 195 GB
- **Downloads**: 30069
- **Stars**: 0
- **Last updated**: 2026-10-28
Source: https://www.modelscope.cn/datasets/Robbyant-Research/BiDex-100
---
A comprehensive benchmark for bimanual dexterous manipulation across 100+ simulation tasks


## Overview
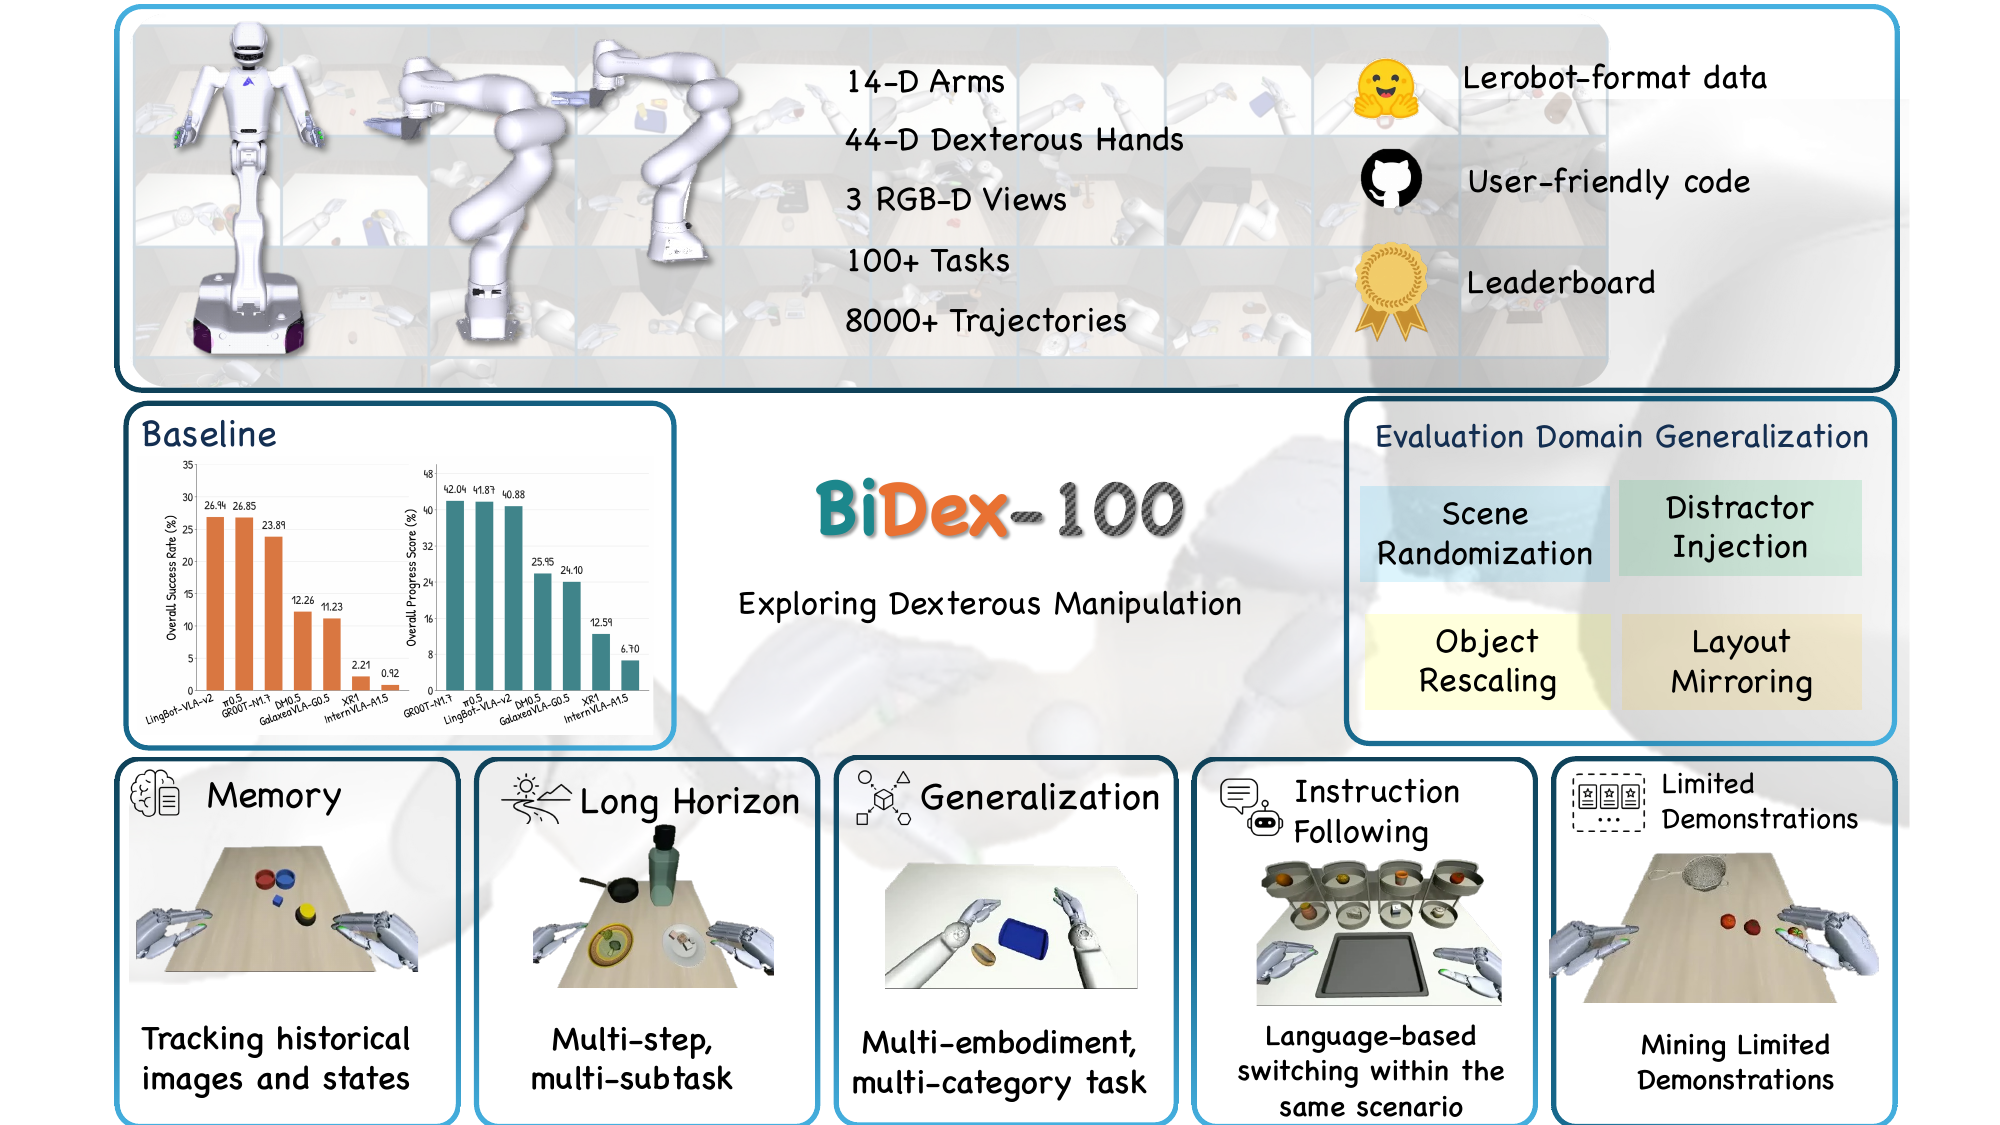
BiDex-100 evaluates vision-language-action policies on coordinated, bimanual,
dexterous manipulation. It combines declarative task definitions, reproducible
MuJoCo environments, matched in-domain and out-of-domain evaluation, 3D assets,
and 8,080 success-validated demonstrations.
- **106 tasks across five capability axes:** Memory, Long-Horizon,
Instruction-Following, Limited-Demonstrations, and Generalization.
- **Two bimanual embodiments:** dual Franka FR3 v2 arms and Astribot S1,
both equipped with dexterous hands.
- **8,080 demonstrations and 6.25M frames:** six synchronized RGB-D streams at
25 FPS, released as task-level LeRobot v2.1 and v3.0 datasets.
- **58-D unified action space:** 14 arm/end-effector dimensions plus 44
dexterous-hand joint dimensions.
- **Matched ID/OOD protocol:** deterministic seeds, scene and object shifts,
predicate-based progress scoring, and a strict score-100 success criterion.
The same trajectories are provided in two LeRobot-compatible layouts:
- `datasets/lerobotv21/`
- `datasets/lerobotv30/`
These directories are alternative representations of the same dataset and should not be counted as separate demonstrations.
## Dataset Overview
| Category | Tasks | Episodes | Frames | Duration |
| --- | ---: | ---: | ---: | ---: |
| Generalization | 40 | 4,000 | 2,720,517 | 30.23 h |
| Instruction Following | 20 | 1,300 | 663,275 | 7.37 h |
| Limited Demonstrations | 26 | 780 | 387,591 | 4.31 h |
| Long Horizon | 10 | 1,000 | 1,242,818 | 13.81 h |
| Memory | 10 | 1,000 | 1,234,772 | 13.72 h |
| **Total** | **106** | **8,080** | **6,248,973** | **69.43 h** |
All trajectories are recorded at 25 FPS.
## Robot Configurations
| Robot type | Number of tasks |
| --- | ---: |
| `dual_fr3v2_sharpa` | 96 |
| `astribot_s1_fixed_sharpa` | 10 |
## Data Modalities
Each task contains six synchronized video streams:
- `observation.images.head_color`
- `observation.images.head_depth`
- `observation.images.left_wrist_color`
- `observation.images.left_wrist_depth`
- `observation.images.right_wrist_color`
- `observation.images.right_wrist_depth`
The videos are stored at 480 × 360 resolution and 25 FPS using H.264 encoding.
The structured observations and actions include:
| Group | Fields |
| --- | --- |
| End-effector state | Absolute poses for both arms, including camera-frame poses |
| Dexterous-hand state | Joint positions and velocities for 44 hand joints |
| Arm state | Joint positions and velocities for 14 arm joints |
| Actions | End-effector poses, 44-dimensional hand commands, and 14-dimensional arm commands |
Exact schemas, dimensions, paths, and data types are recorded in each task's `meta/info.json`.
## Repository Structure
```text
BiDex-100/
├── README.md
├── assets/
│ ├── README.md
│ ├── LICENSE
│ ├── articraft_objects/
│ ├── assembly_objects/
│ ├── astribot_descriptions/
│ ├── libero/
│ └── robocasa_assets/
└── datasets/
├── lerobotv21/
│ ├── Generalization/
│ ├── Instruction_Following/
│ ├── Limited_Demonstrations/
│ ├── Long_Horizon/
│ └── Memory/
└── lerobotv30/
├── Generalization/
├── Instruction_Following/
├── Limited_Demonstrations/
├── Long_Horizon/
└── Memory/
```
Each category contains one directory per task. A typical task directory contains:
```text
/
├── data/
├── videos/
└── meta/
├── episodes.jsonl
├── episodes_stats.jsonl
├── info.json
└── tasks.jsonl
```
The precise data and video paths differ between the two LeRobot layouts. Applications should read the `data_path` and `video_path` templates from `meta/info.json`.
## Storage
| Component | Approximate size |
| --- | ---: |
| `datasets/lerobotv21/` | 95.66 GiB |
| `datasets/lerobotv30/` | 93.89 GiB |
| `assets/` | 5.45 GiB |
| **Complete repository** | **195.00 GiB** |
Download only the representation and categories needed for your experiments when possible.
## Download
Run the download scripts from the [BiDex-100 code repository](https://github.com/robbyant-research/BiDex-100):
```bash
git clone https://github.com/robbyant-research/BiDex-100.git
cd BiDex-100
```
The release is available on [Hugging Face](https://huggingface.co/datasets/Robbyant-Research/BiDex-100) and [ModelScope](https://modelscope.cn/datasets/Robbyant-Research/BiDex-100), with the same three independently downloadable components:
```text
assets/ compressed simulation asset packs
datasets/lerobotv21/ LeRobot v2.1 datasets
datasets/lerobotv30/ LeRobot v3.0 datasets
```
Download everything from Hugging Face (the default source) and prepare the simulation assets:
```bash
python -m pip install -U huggingface_hub
hf auth login # omit for public, unauthenticated downloads
bash scripts/download_release.sh all downloads/BiDex-100
bash scripts/setup_assets_links.sh downloads/BiDex-100
```
To download from ModelScope instead, install its CLI and select the source:
```bash
python -m pip install -U modelscope
bash scripts/download_release.sh --source modelscope all downloads/BiDex-100
bash scripts/setup_assets_links.sh downloads/BiDex-100
```
Public ModelScope downloads do not require login. Each component can instead be downloaded separately into the same destination:
```bash
bash scripts/download_release.sh assets downloads/BiDex-100
bash scripts/download_release.sh lerobotv21 downloads/BiDex-100
bash scripts/download_release.sh lerobotv30 downloads/BiDex-100
# The same component selection works with ModelScope.
bash scripts/download_release.sh --source modelscope assets downloads/BiDex-100
bash scripts/download_release.sh --source modelscope lerobotv21 downloads/BiDex-100
bash scripts/download_release.sh --source modelscope lerobotv30 downloads/BiDex-100
```
`scripts/download_assets.sh` and `scripts/download_datasets.sh` remain as convenience wrappers. Run `download_datasets.sh lerobotv21`, `download_datasets.sh lerobotv30`, or `download_datasets.sh all` to fetch one or both dataset formats. The download destination preserves the repository layout shown above.
Both wrappers accept `--source modelscope` before their positional arguments:
```bash
bash scripts/download_assets.sh --source modelscope downloads/BiDex-100
bash scripts/download_datasets.sh --source modelscope all downloads/BiDex-100
```
Set `BIDEX_DOWNLOAD_SOURCE=modelscope` to select ModelScope by default; `--source` overrides this setting. `BIDEX_HF_REPO` and `BIDEX_MODELSCOPE_REPO` override the repository ID for their respective source (both default to `Robbyant-Research/BiDex-100`). Rerun the same command to reuse downloaded files and resume an interrupted download. After downloading, the script checks for all five asset packs or all 106 task directories per selected dataset format, including task metadata, Parquet data, and videos.
The asset setup script accepts either `downloads/BiDex-100` or `downloads/BiDex-100/assets`. It extracts each archive in place, creates the repository links, and recreates the relative aliases used by assembly tasks. It is idempotent, so an interrupted setup can be rerun safely. Alternatively set `BIDEX_ASSETS=/path/to/BiDex-100/assets`. Export `HF_TOKEN` instead of using `hf auth login` in non-interactive environments.
For full simulation installation instructions, see the [setup guide](https://github.com/robbyant-research/BiDex-100/blob/master/docs/DOCUMENT.md#installation).
## Assets
The `assets/` directory contains the scene, object, robot-description, texture, and mesh resources used by the BiDex-100 simulation benchmark.
## License
The trajectory data and metadata in both dataset layouts are licensed under the
**Creative Commons Attribution-NonCommercial 4.0 International License
(CC BY-NC 4.0)**:
- [`datasets/lerobotv21/LICENSE`](datasets/lerobotv21/LICENSE)
- [`datasets/lerobotv30/LICENSE`](datasets/lerobotv30/LICENSE)
Appropriate attribution is required, and commercial use is not permitted
without separate permission.
Asset licensing is component-specific. Original BiDex-100 assets are licensed
under CC BY-NC 4.0, while third-party assets retain their upstream terms. See
[`assets/README.md`](assets/README.md), [`assets/LICENSE`](assets/LICENSE), and
the notices in each asset directory.
## Dataset Limitations
- The trajectories were generated in simulation and may not directly reflect real-world sensing, dynamics, or control noise.
- Performance on these tasks should not be treated as evidence of unrestricted real-world robotic capability.
- The two LeRobot directories contain alternative representations of the same trajectories.
- Users are responsible for reviewing the applicable licenses before redistribution or commercial use.
## Citation
```bibtex
@article{wang2026bidex,
title={BiDex-100: A Comprehensive Benchmark for Bimanual Dexterous Manipulation Across 100+ Simulation Tasks},
author={Wang, Yong and Zheng, Kecheng and Zhu, Xing and Xu, Chao and Shen, Yujun and Cai, Shengze},
journal={arXiv preprint arXiv:2610.25459},
year={2026}
}
```